
 Contact
 Comment faire ses achats

Livraison
Guide d'achat
Indoor Mobile Robot Path Planning Algorithm
 Anglais
 172 b
Jusqu'à 30 jours pour les retours
Les clients ont également acheté

 /
 Livre de poche
 15.18
€






 /
Livre de poche
13.57
€

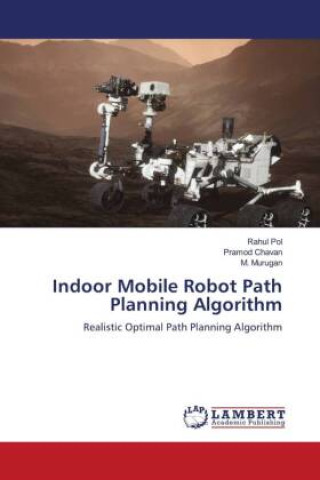
This book is focused on the development of novel path finding algorithms which overcomes the traditional path finding algorithm shortcoming and making more realistic end solution for a variety of robotic and game development application. The proposed novel "Realistic Optimal Path Planning Algorithm" (ROPPA), utilize cell pruning techniques to improve the explored path length. Also this method takes care of future non-collision of mobile robot with in-path obstacle, while utilizing the uniquely designed set of rules.This book incorporated analytic bounds to compare the path length of true shortest with the path cost found from the traditional path finding algorithm over the uniform square two dimensional grid maps. The research also introduces and validates the implementation of realistic optimal path planning algorithm that disseminates information along the grid edges and vertices during path exploration. Thus this method overcomes the traditional grid edges or vertices constraint which reduces the overall computation time and final explore path length. To maintain the safer distance.


À propos du livre
Anglais
Catégories

Offrez ce livre dès aujourd'hui
C’est simple
1 Ajouter au panier et choisir l'option Livrer comme cadeau à la caisse. 2 Nous vous enverrons un bon d'achat 3 Le livre arrivera à l'adresse du destinataireCeci pourrait également vous intéresser
 /
Livre relié
207.28
€
 /
Livre de poche
14.17
€



 /
Livre de poche
10.25
€
 /
Livre relié
33.39
€

 /
Livre de poche
49.57
€


 /
Livre de poche
310.16
€
Bonjour ! Je suis Libroamiko, votre conseiller littéraire.
Comment puis-je vous aider ?