
 Contact
 Comment faire ses achats

Livraison
Guide d'achat
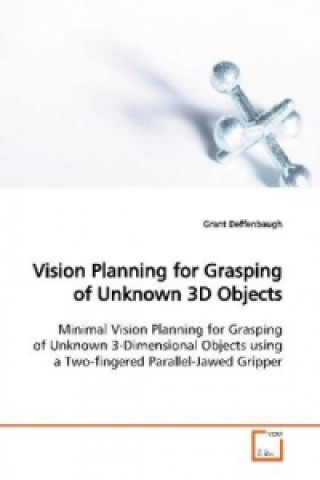
Vision Planning for Grasping of Unknown 3D Objects
Minimal Vision Planning for Grasping of Unknown 3-Dimensional Objects using a Two-fingered Parallel-Jawed Gripper
 Anglais
 120 b
Jusqu'à 30 jours pour les retours
Les clients ont également acheté

 /
 Livre de poche
 13.47
€


 /
Livre de poche
9.05
€


 /
Livre de poche
14.27
€
 /
Livre de poche
69.99
€
 /
Livre de poche
33.39
€

 /
Livre de poche
13.67
€

Vision planners used for grasping attempt to either§recognize or reconstruct the object to be grasped.§Recognition systems, while needing only a few images,§have difficulty with unknown objects, and§reconstruction systems, while being able to grasp§unknown objects, require several images to construct§a CAD level model of the object. By incorporating the§grasp planner with the view planner, a system is§developed that can grasp unknown three-dimensional§objects while generally requiring only a few images. §§A system using off-the-shelf components without§relying upon structured light, lasers, or a stereo§camera system is proposed. As the surface of the§object is being modeled, a grasp plan is formulated§for an antipodal grasp. The position for the next§best view is determined by the view location that§will most likely acquire the missing information§required to a stable grasp.§§The minimal view criteria for grasping an object are§given and it is shown that any shape can be held by a§compliant two-fingered parallel-jawed gripper. Using§the view criteria and view planning system it is§possible to predict the number of required views§necessary to plan a stable grasp of a given object.


À propos du livre
Anglais

Offrez ce livre dès aujourd'hui
C’est simple
1 Ajouter au panier et choisir l'option Livrer comme cadeau à la caisse. 2 Nous vous enverrons un bon d'achat 3 Le livre arrivera à l'adresse du destinataireCeci pourrait également vous intéresser


 /
Livre de poche
6.23
€
 /
Livre de poche
8.54
€


 /
Livre de poche
18.30
€



 /
Livre relié
21.51
€


Bonjour ! Je suis Libroamiko, votre conseiller littéraire.
Comment puis-je vous aider ?