
 Contact
 Hoe winkelen bij ons werkt

Bezorging
Winkelgids
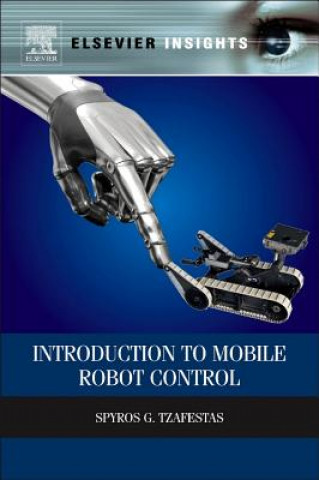
Introduction to Mobile Robot Control
 Engels
 275 b
Tot 30 dagen retourrecht
Dit vind je misschien ook interessant












 /
 Gebonden
 33.23
€


Introduction to Mobile Robot Control provides a complete and concise study of modeling, control, and navigation methods for wheeled non-holonomic and omnidirectional mobile robots and manipulators. The book begins with a study of mobile robot drives and corresponding kinematic and dynamic models, and discusses the sensors used in mobile robotics. It then examines a variety of model-based, model-free, and vision-based controllers with unified proof of their stabilization and tracking performance, also addressing the problems of path, motion, and task planning, along with localization and mapping topics. The book provides a host of experimental results, a conceptual overview of systemic and software mobile robot control architectures, and a tour of the use of wheeled mobile robots and manipulators in industry and society.§Introduction to Mobile Robot Control is an essential reference, and is also a textbook suitable as a supplement for many university robotics courses. It is accessible to all and can be used as a reference for professionals and researchers in the mobile robotics field. §Clearly and authoritatively presents mobile robot concepts §Richly illustrated throughout with figures and examples §Key concepts demonstrated with a host of experimental and simulation examples §No prior knowledge of the subject is required; each chapter commences with an introduction and background


Informatie over het boek
Engels

Geef dit boek vandaag nog cadeau
Dat gaat heel eenvoudig
1 Voeg het boek toe aan je winkelwagentje en selecteer Als cadeau bezorgen 2 Je krijgt van ons per omgaand een voucher 3 Het boek wordt bezorgd op het adres van de ontvangerHoi! Ik ben Libroamiko, je boekadviseur.
Hoe kan ik je helpen?